Aditya Kothari
Robotics & Autonomy Researcher
Making robots learn skills from vision alone

Stanford University
Multi-Robot Systems Lab · MS AeroAstro · GPA 4.0
Robotics & Autonomy Researcher
Making robots learn skills from vision alone
I'm an MS student in Aeronautics & Astronautics at Stanford, working in the Multi-Robot Systems Lab under Prof. Mac Schwager. I build visuomotor policies for flight: systems that map raw onboard camera frames to control, trained in photorealistic 3D Gaussian Splat reconstructions and transferred to hardware. Most recently I was an autonomy intern at Archer Aviation, where I built a multi-agent planner for swarm-level probabilistic search. Before Stanford I graduated top of my class from VIT, led a 25-member university robotics team that fielded 7 UAVs and ground robots, and held engineering roles at Boeing and Tata Motors.
Leading development of AORA, an agentic orchestrator that turns policy training into a closed self-improvement loop: it provisions cloud compute, trains and evaluates vision-language-action (VLA) policies through an agentic “Forge,” and feeds failures back into the next round without a human supervising, with full sim-to-real onto a Unitree G1 humanoid. Alongside it I design system-2 visuomotor policies for language-guided drone navigation, trained entirely in 3D Gaussian Splat simulation, removing the 60+ hours of manual flying such policies would otherwise require.
Broader Research Interests
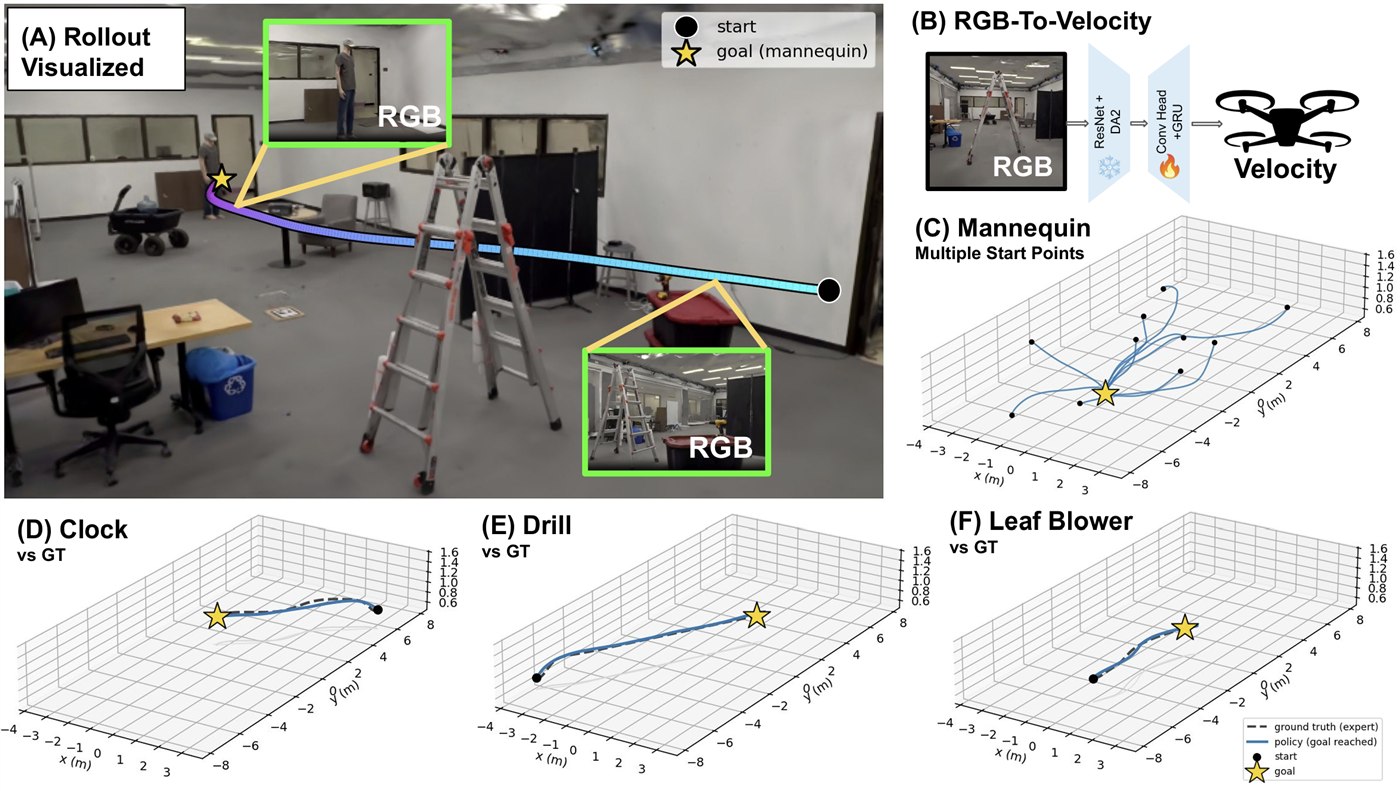
A quadrotor that flies to a goal through cluttered space using nothing but a forward camera. No map, no depth sensor, no full state estimate. Team project with 2 teammates.
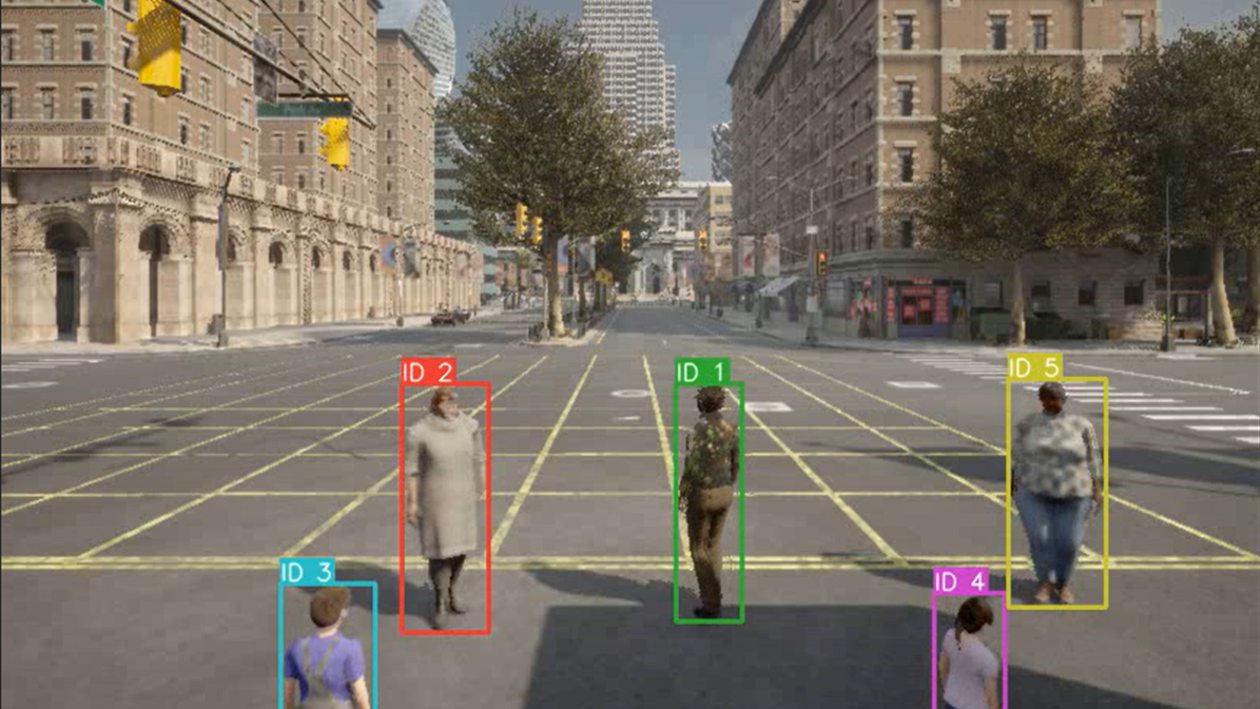
An IMM-based tracker that blends motion models and social dynamics to accurately track multiple objects in 3D.
Probabilistic localization for lunar rovers using star pattern recognition and particle filtering from sky imagery alone.
A decoupled policy architecture for long-horizon manipulation that remains stable under significant perception noise.
A complete on-robot autonomy system for indoor navigation in cluttered, dynamic environments with moving obstacles.
MS in Aeronautics & Astronautics · GPA 4.0 / 4.0
Sep 2025 – Mar 2027
Robot Autonomy (Multi-Robot Systems) · State Estimation · Deep Reinforcement Learning · Computer Vision
BS in Mechanical Engineering · GPA 4.0 / 4.0
Jul 2021 – Jul 2025
Graduated top of class · Merit Scholarship '22–'25 · Student Achiever '24 & '25
One of India's most selective postgraduate fellowships, for graduate study abroad
2025National fellowship, KC Mahindra Education Trust
2025Jain International Trade Organization postgraduate fellowship
2025National winner. INR 300,000 prize, autonomous eVTOL systems integration
Nov 2023Ranked 1st of 200+ participants nationwide
Mar 2024National runner-up. INR 50,000 prize
Mar 2023Top 3 nationally. Dynamic braking safety system for inclined runways
Feb 2024Earlier work in aerospace materials and mechanical systems, from my undergraduate research.
If you're building in autonomy or robot learning, let's talk.